Physical AI connects models to consequential actions
Physical AI describes systems that perceive and act in physical environments, including robots, autonomous machines, and embodied AI applications. Unlike a text-only assistant, a physical system can move, manipulate objects, or interact with equipment. A perception error may therefore affect safety, quality, or throughput. CTOs should evaluate the complete chain from sensors to action rather than treating the model as an isolated component.
That chain can include cameras, LiDAR, sensor fusion, a world model, planning, low-level control, and human supervision. Every stage has its own failure modes and timing requirements. A robot may identify an object correctly but plan an unsafe route, or execute a sound plan using stale sensor data. Map the intended operating domain, expected variation, prohibited actions, and intervention path before deciding what to automate.
Make LiDAR and multi-camera data reliable
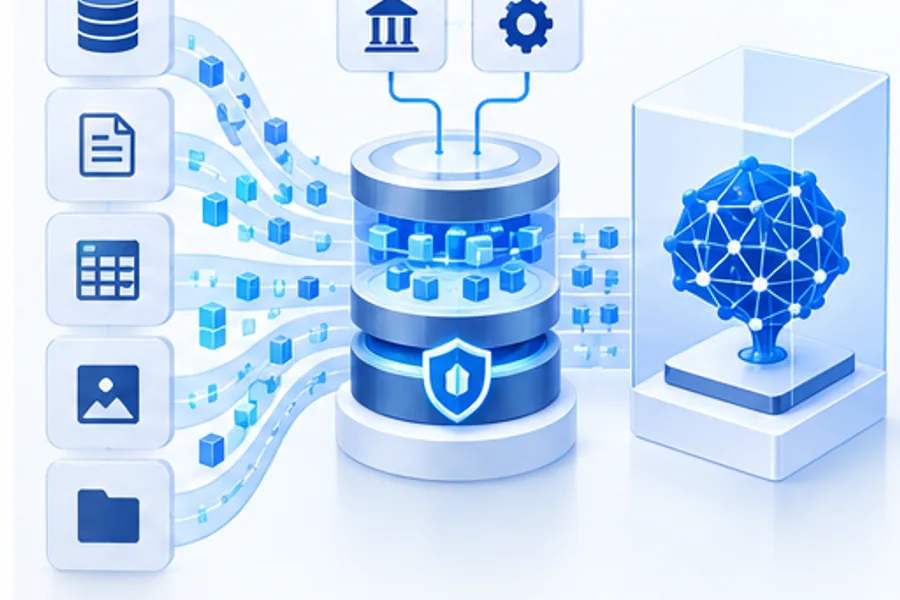
LiDAR point-cloud annotation can support object detection, localization, mapping, and scene understanding. Teams need consistent labels, coordinate conventions, temporal alignment, and clear handling of occlusion and uncertain boundaries. Annotation tools and quality procedures should preserve sensor timestamps and calibration context. If the labels cannot be related back to the original frames and sensor configuration, evaluation results may be difficult to reproduce or debug.
Multi-camera sensor fusion adds synchronization and calibration challenges. A combined scene representation should account for changing viewpoints, missing frames, lighting, motion blur, and sensor disagreement. Define when the system should trust a sensor, lower confidence, or pause. Review coverage across operating locations, weather, time of day, object density, and relevant equipment states. A benchmark from one clean environment is not evidence of reliability across every facility.
Use demonstrations and world models with clear limits
Robot demonstration trajectories show how an operator performs a task and can help train or evaluate a policy. Record the goal, initial conditions, actions, observations, success criteria, and recovery behavior. Include more than ideal runs: safe corrections, abandoned attempts, and variations in object placement can reveal whether a policy learned a robust task or merely replayed a familiar sequence. Protect workers and remove personal data from recordings where appropriate.
World-model rollouts and simulation let teams explore scenarios without repeatedly using physical hardware. They are valuable for coverage, regression testing, and controlled stress tests, but their value depends on how well the simulated dynamics match reality. Track which conditions are represented, compare predictions with real sensor and interaction logs, and treat sim-to-real gaps as explicit risks. Validate changes on approved hardware under controlled conditions before increasing autonomy.
Evaluate safety, recovery, and human intervention
Define safe operating boundaries in terms the system can enforce: permitted zones, speed or force limits, restricted objects, stopping conditions, and recovery procedures. Test sensor loss, communication delays, blocked routes, unexpected movement, conflicting commands, and emergency stops. Measure task success alongside near misses, unsafe attempts, intervention frequency, and time to reach a safe state. A high completion score is not acceptable if the robot routinely approaches a boundary or depends on an operator to prevent harm.
Human supervision needs a useful interface and a clear authority model. Operators should understand what the system is attempting, see relevant sensor state, pause or take control, and report failures without disrupting safety procedures. Train people for the intervention role and test their workload under realistic conditions. Define who can restart after a fault and what evidence is required. Do not assume that a manual override alone makes an unsafe process safe.
Move from lab evaluation to operational readiness
Start with a bounded task, approved site, representative data, and named safety and operations owners. Use staged trials: offline data review, simulation, supervised hardware tests, a limited operating cohort, and then expansion if pre-agreed criteria are met. Maintain versioned sensor configurations, model and policy versions, test results, and interaction logs. Privacy and retention controls should be planned before collecting video or workplace telemetry.
FIX Intelligence, part of FIX Solutions JSC, can support AI data engineering, model development, evaluation, and integration across connected business systems. For physical AI, the right engagement may include data annotation design, test infrastructure, simulation evaluation, or system integration. Keep a rollback path and review incidents before broadening the operating domain. Successful deployment is a sustained engineering and safety capability, not a single robotics demonstration.
Prepare the site, workforce, and operating model
A deployment site introduces constraints that a lab cannot fully represent: floor layout, human traffic, lighting, connectivity, equipment variation, maintenance access, and local operating procedures. Work with site operators to map these conditions and define restricted zones, start-up checks, emergency processes, and responsibilities during a shift. Review training needs so staff understand the robot’s capability and limitations rather than treating it as either infallible or unpredictable.
Plan how sensor and interaction data will be handled, including notices, permitted purposes, retention, and access. Coordinate engineering and safety reviews with the organization’s relevant specialists; physical AI may touch workplace, product, or sector-specific requirements. Set a small operating boundary and review incidents, near misses, and interventions before changing it. The organization should be able to stop a deployment without losing the records needed to investigate what happened.
Make the business case with operational measures
A robotics business case should compare the complete operating workflow, not just robot utilization or labor hours. Include setup, integration, maintenance, downtime, safety procedures, human supervision, exception handling, and changes to the facility. Select an outcome such as safer inspection coverage, reduced repetitive handling, or more consistent process data, and establish a baseline before a pilot. Avoid claiming savings until the measured process supports them.
Plan for ownership over the equipment and software lifecycle. Decide who manages model updates, sensor calibration, spare parts, incident review, and integration changes. A site pilot can reveal whether the process is technically feasible and operationally acceptable; it should also identify what training, staffing, or layout changes are needed. These findings let finance and operations compare scale-up options with realistic costs and responsibilities.